BUILDING
INDUSTRY
BEYOND EARTH.
Building the autonomous robotic systems that will construct, maintain and expand the factories of tomorrow, beyond Earth.
SPACE CANNOT SCALE
WITHOUT INDUSTRY.
Space infrastructure cannot scale if every factory, station and structure must be launched complete from Earth.
Launch Dependence
Large orbital structures are fundamentally constrained by payload mass, fairing volume, structural acoustic loads, and prohibitive recurring launch costs.
Human Construction Limits
Deep-space industrial construction cannot depend on astronauts for hazardous, high-radiation, microgravity assembly, continuous inspection, maintenance, and repair tasks.
Missing Local Industry
Future lunar, Martian, asteroid, and deep-space missions require local manufacturing, in-situ materials processing, spacecraft servicing, and autonomous infrastructure expansion.
“The next leap is not only reaching space. It is building, repairing and manufacturing there.”
THE MACHINES
THAT BUILD THE FACTORY.
Vinastra is developing the Autonomous Space Construction System, an AI, robotics and digital-twin platform designed to support the construction of factory modules beyond Earth.
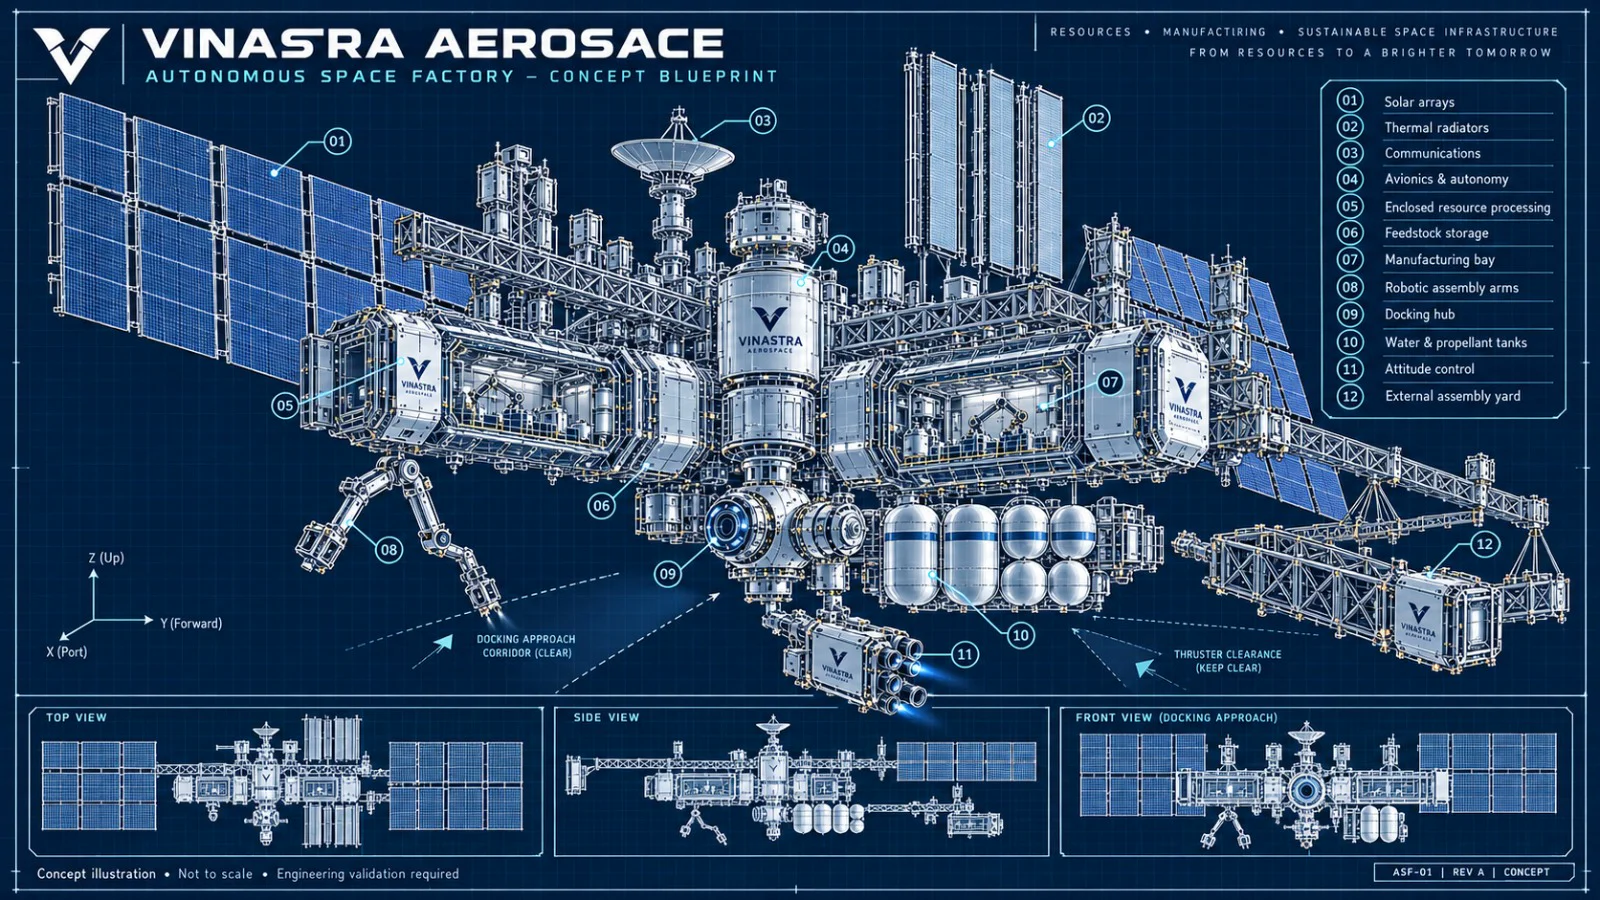
Task sequencing, dynamic construction path planning, autonomous anomaly response, and multi-agent decision support.
Factory blueprints, real-time kinematic simulation, virtual-to-physical comparison, assembly progress verification, and anomaly tracking.
Multi-DOF robotic arms, mobile robotic platforms, additive manufacturing print-heads, structural component positioning, and autonomous joining.
Sub-millimeter optical metrology, LiDAR structural alignment, visual defect inspection, closed-loop quality assurance, and real-time fault detection.
Mission health monitoring, high-level supervisory commands, secure telemetry downlinks, exception review, and ground recovery instructions.
FROM DIGITAL BLUEPRINT
TO PHYSICAL INFRASTRUCTURE.
The robot fleet follows a pre-installed construction plan, executing coordinated workflows while retaining AI-assisted replanning and ground-supervised recovery.
Load verified factory CAD blueprints, establish task sequences, and compute collision-free robotic trajectory paths.
Navigate robotic mobility platforms, dock structural nodes, position components, and align assembly fixtures.
Demonstrate additive manufacturing and feedstock handling for structural connectors, brackets, and test trusses.
Position, join, lock, and integrate modular structural elements using multi-axis coordinated robotic end-effectors.
Deploy machine-vision cameras, sensor arrays, and optical metrology to compare physical assemblies against digital twin tolerances.
Trigger AI-assisted replanning or ground-control supervisory recovery action whenever a geometric anomaly is flagged.
Onboard AI robots execute planned assembly, joining, and metrology sequences independently without communication latency dependencies.
If minor misalignment occurs, onboard computer vision calculates corrective trajectories and replans assembly steps autonomously.
For unresolvable variances, robotic units enter a safe holding state, transmitting full diagnostic telemetry to Earth mission control for evaluation.
A FACTORY
BEYOND EARTH.
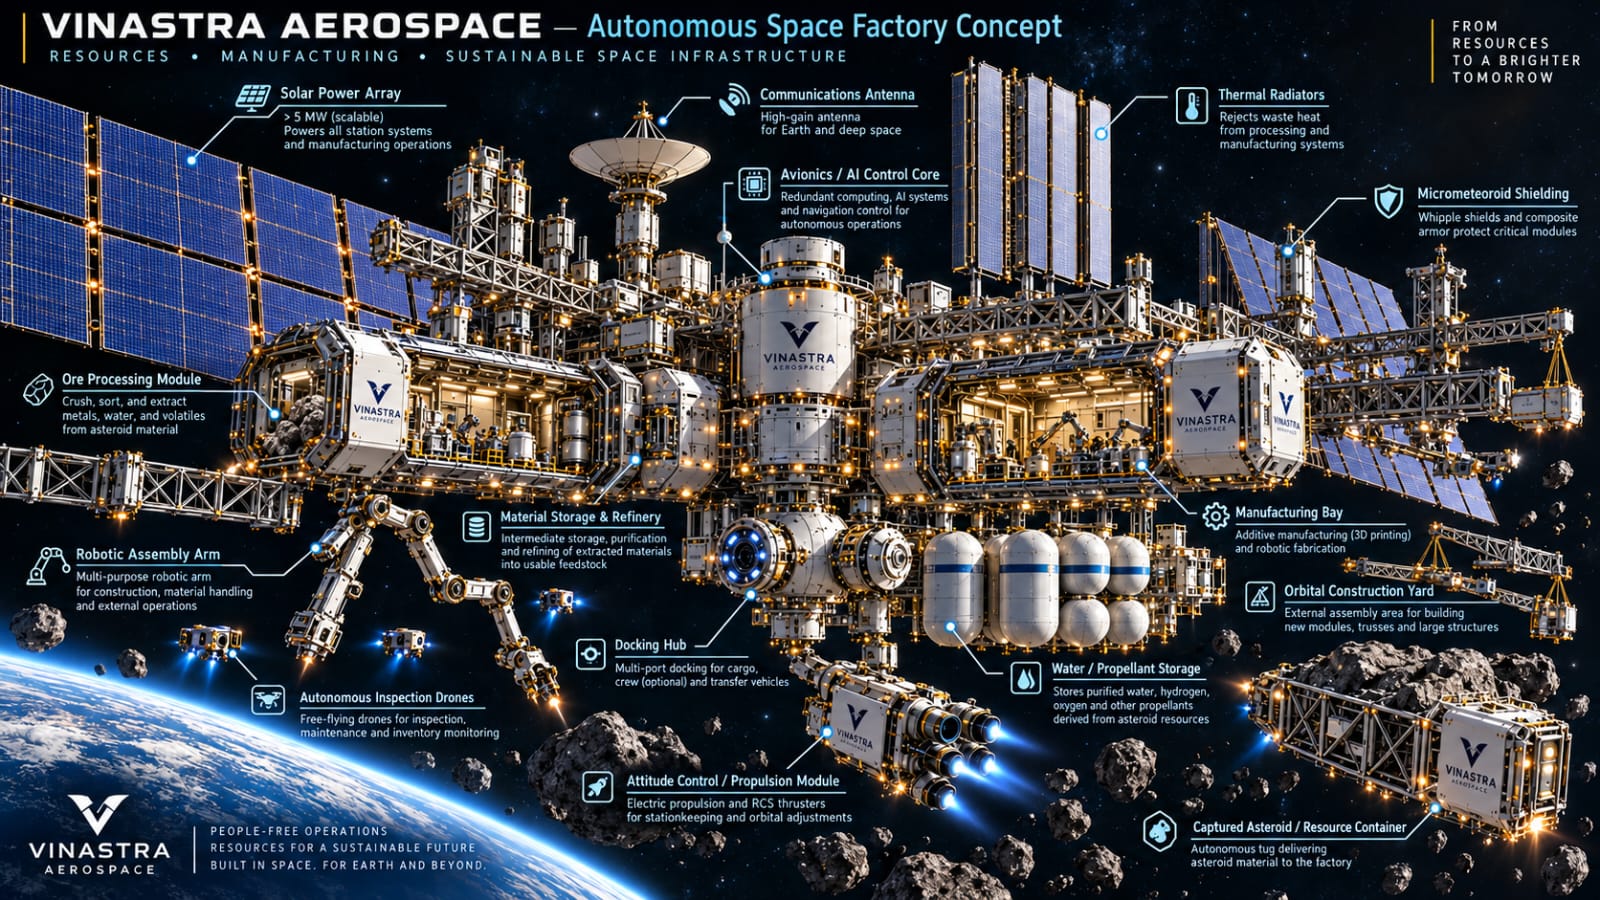
A proposed modular, autonomous industrial platform designed to process resources, manufacture useful products, support spacecraft servicing, and expand future space infrastructure.
In-Space Manufacturing
Robotic 3D printing and advanced additive manufacturing of structural components, replacement parts, tooling, and large space infrastructure elements.
Asteroid Resource Processing
Receiving materials from future asteroid-mining missions, separating mineral volatiles, and refining usable metals into manufacturing feedstock.
Spacecraft Servicing
Robotic inspection, modular component replacement, structural refurbishment, and life-extension servicing for satellites and interplanetary transfer vehicles.
Logistics & Fuel Depot
Exploring deep-space propellant storage, cryogenic fuel transfer infrastructure, standardized docking interfaces, and orbital logistics coordination.
Space R&D Laboratories
Enclosed pressurized and unpressurized laboratories supporting microgravity materials science, crystal growth, and autonomous robotics validation.
Moon & Mars Mission Support
Supplying manufactured structural trusses, replacement components, and logistics payloads for lunar base outposts and Martian transit architectures.
Autonomous Infrastructure
Deploying coordinated robotic builder platforms to assemble additional factory modules and expand orbital platforms without human EVA risks.
Future Commercial Infrastructure
Exploring commercial research platforms, orbital manufacturing services, and industrial infrastructure support for future space economy participants.
FROM ASTEROID DUST
TO INDUSTRIAL FEEDSTOCK.
The long-term vision explores how extraterrestrial resources could become useful feedstock for manufacturing infrastructure in space.
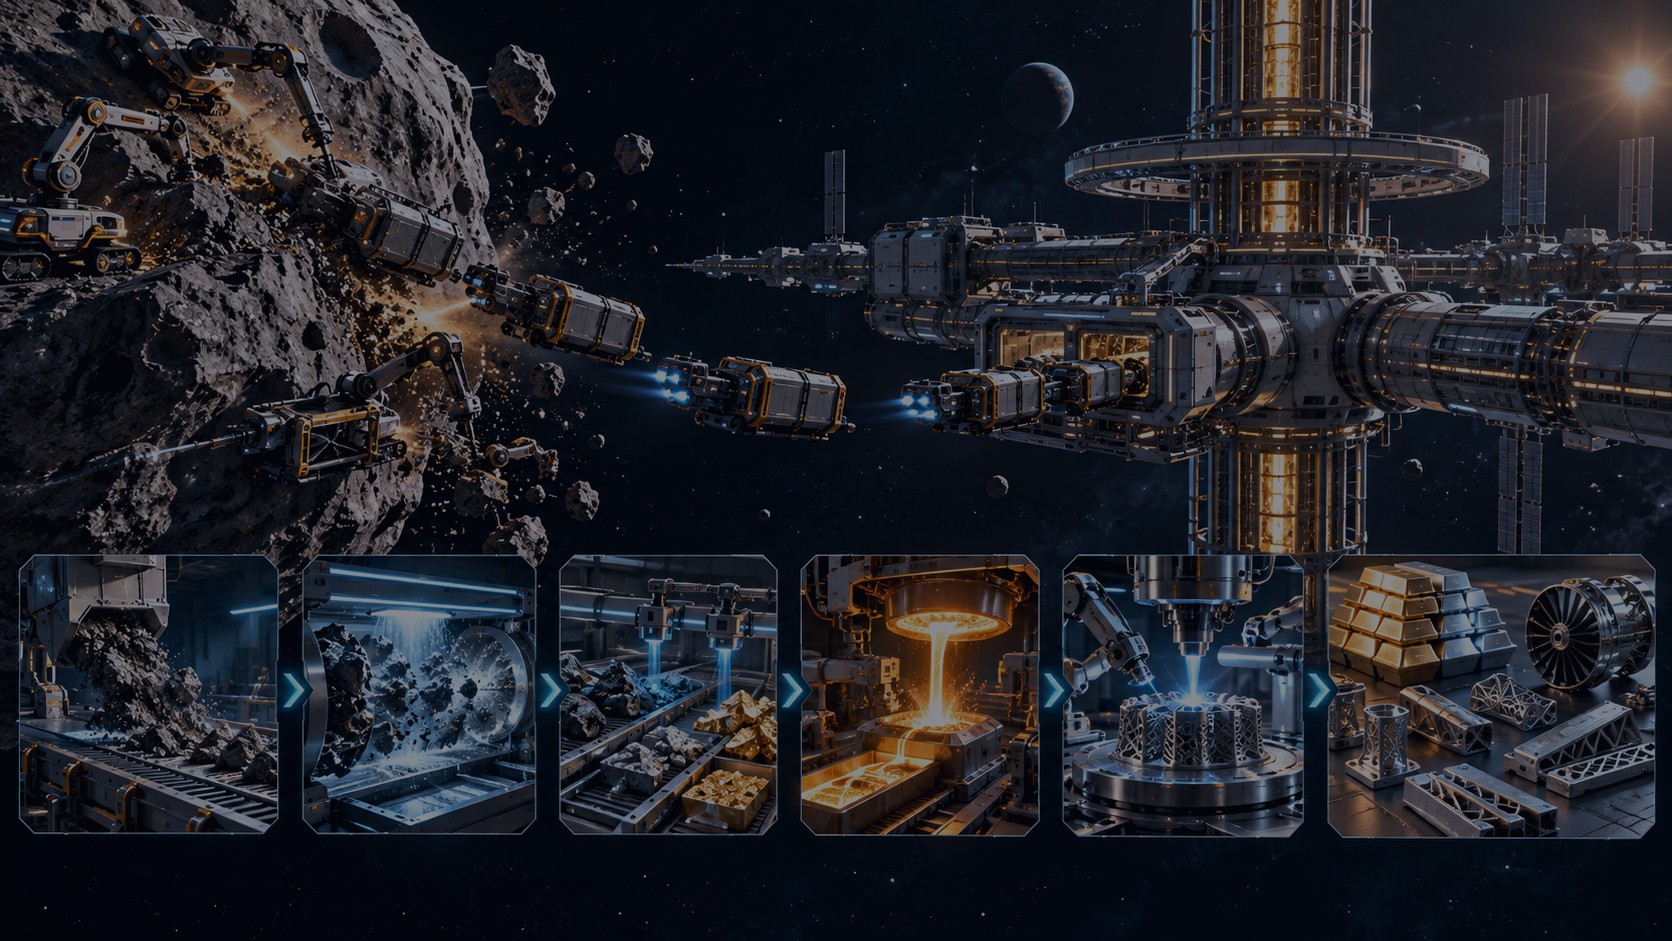
In-situ material prospecting and surface extraction by proposed future robotic mining systems.
Autonomous containment, preparation, and mass stabilization of recovered asteroid regolith.
Transfer of resource containers to future orbital refining and factory processing modules.
Sorting, magnetic separation, thermal extraction of volatiles, and metal refining into feedstock.
Robotic wire-arc additive manufacturing, cold-spray printing, and precision CNC fabrication.
Integration into spacecraft trusses, solar supports, orbital habitats, and deep-space infrastructure.
PROVE IT ON EARTH.
PREPARE FOR SPACE.
Before attempting a space mission, Vinastra plans to develop a ground-based demonstrator of its Autonomous Space Construction System.
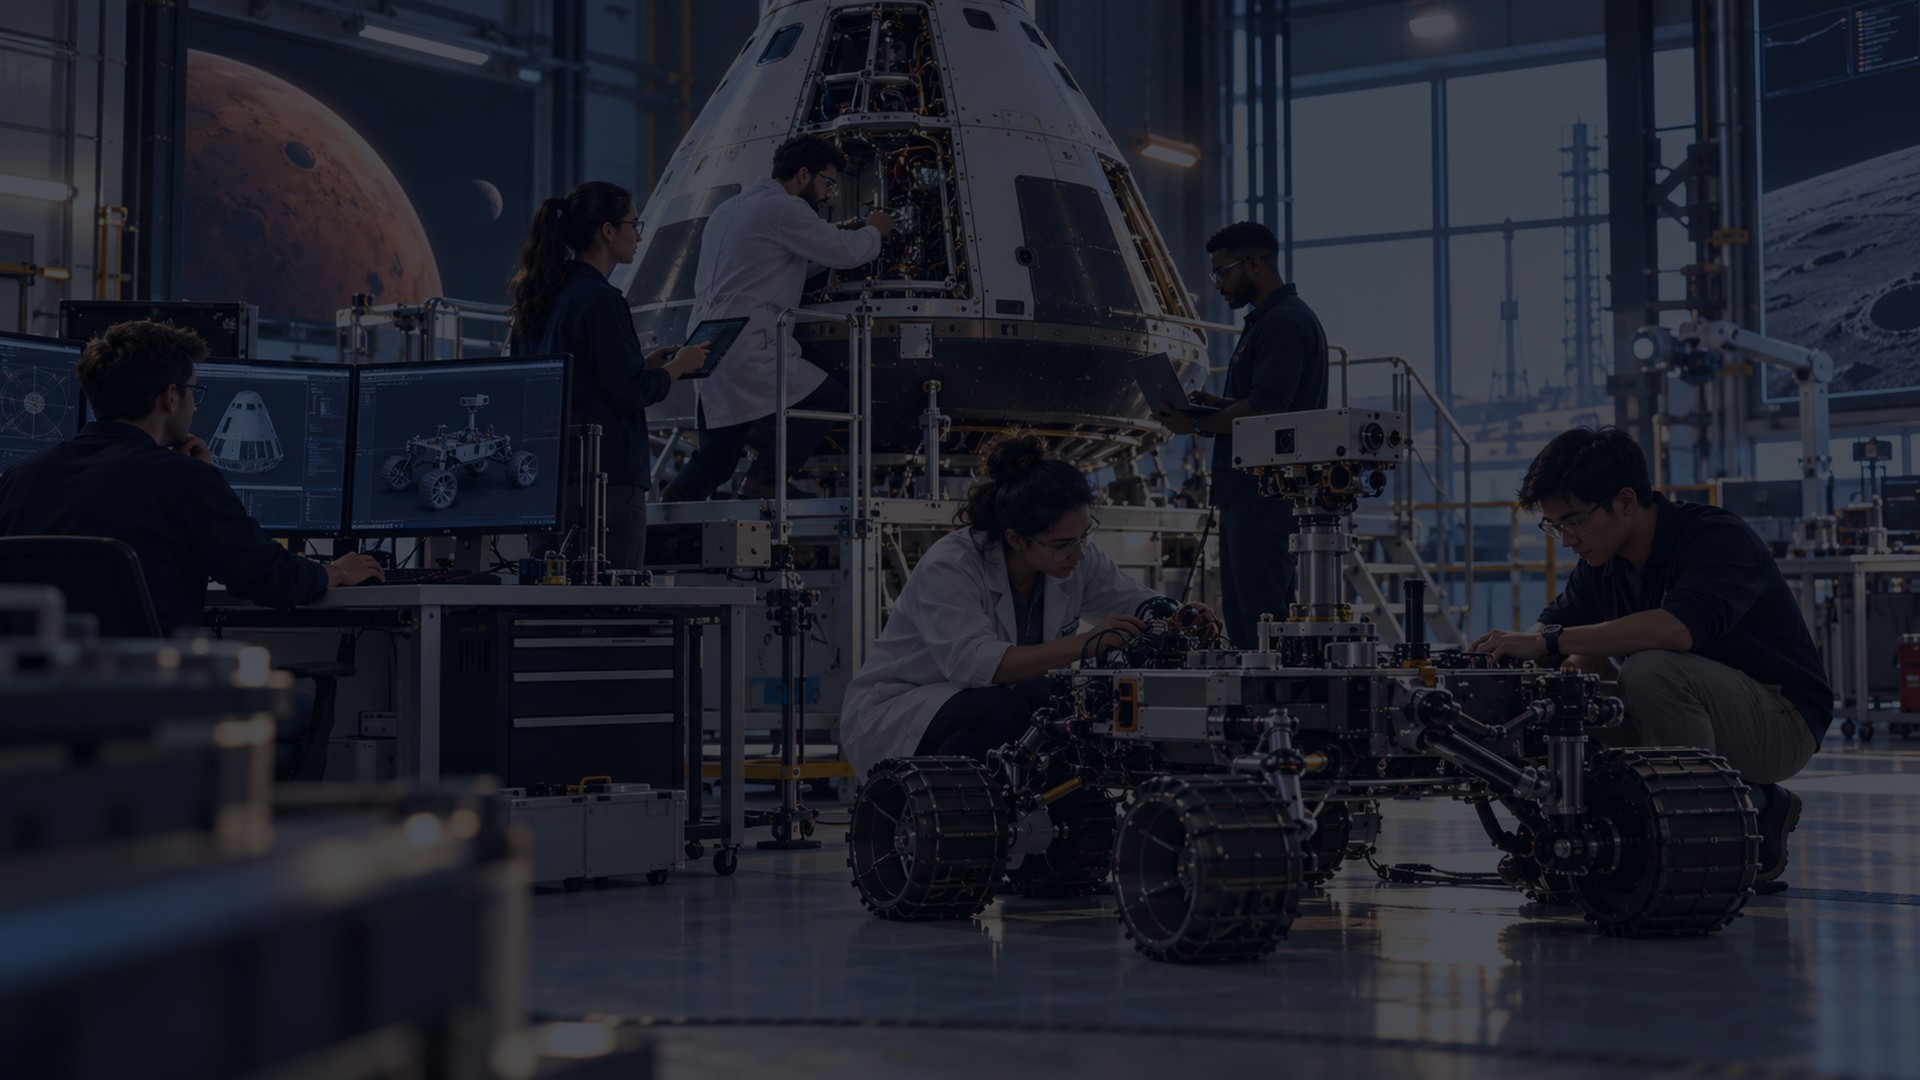
Autonomous Robotic Assembly
Demonstrate coordinated multi-axis robotic positioning, mechanical fastening, and joining of modular structural space elements.
Robotic Additive Manufacturing
Demonstrate 3D printing of structural test components and custom brackets directly integrated into the modular truss framework.
Digital-Twin Verification
Compare the physical ground assembly against the approved digital blueprint in real time with laser metrology and optical sensors.
Closed-Loop Fault Recovery
Detect intentional mechanical misalignment, trigger automated computer vision replanning, and execute corrective joining workflows.
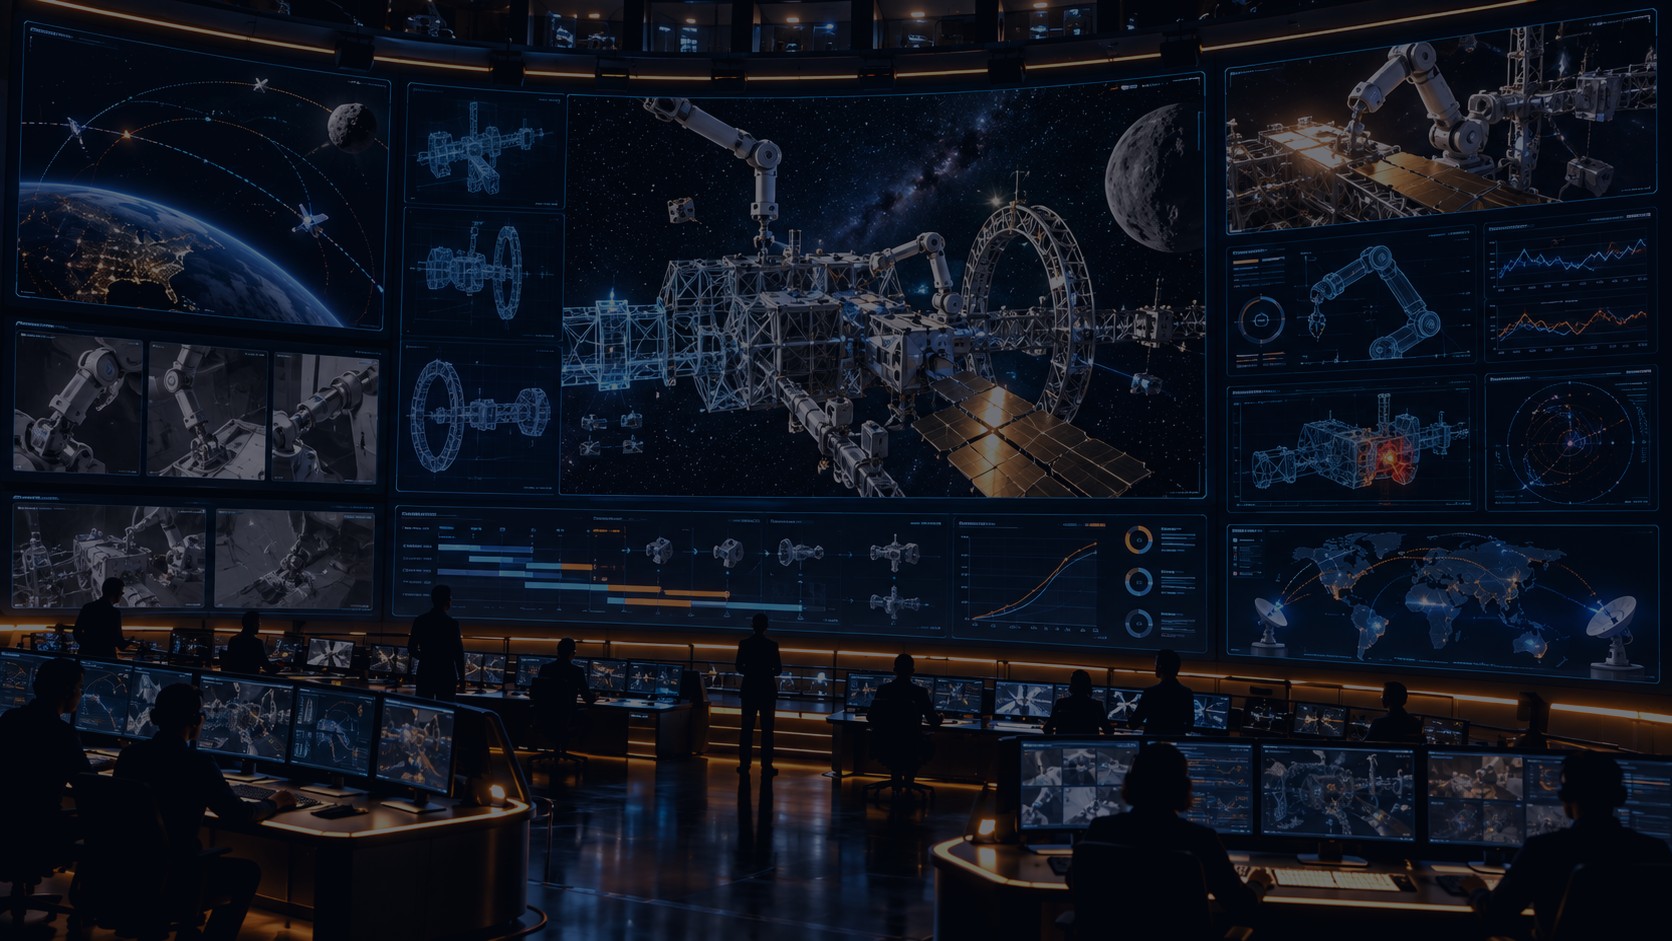
Mission Control Console
Build a comprehensive ground-based monitoring and supervision interface for live telemetry, construction tracking, and human intervention.
AUTONOMOUS BY DESIGN.
SUPERVISED FROM EARTH.
Autonomous systems handle time-critical operations. Ground control supervises mission objectives, reviews exceptions, and provides recovery instructions when communication conditions permit.
FROM RESEARCH
TO SPACE INFRASTRUCTURE.
Technology milestones that translate the long-term vision into an investable, staged engineering progression.
Space factory concept design, feasibility studies, AI robotics R&D, preliminary CAD models, and kinematic simulation.
Robotic assembly systems, autonomous optical inspection, additive manufacturing test-cells, and control software.
Integrated ground demonstrations, environmental testing, thermal-vacuum simulations, and potential orbital payload planning.
Investigate robotic assembly and small-scale manufacturing demonstrations on partner orbital test flights.
Explore resource processing, larger modular factory platforms, satellite servicing, and space logistics hubs.
Pursue scalable autonomous manufacturing and industrial infrastructure beyond Earth orbit.
ASCS concept, preliminary CAD assets, Research Fellowship setup, and academic/industry partner mapping.
Factory-module autonomous construction demonstrator proving robotic positioning and joining.
Robotic 3D printing, closed-loop optical metrology, automated replanning, and supervisory mission UI.
Thermal, vacuum, and analog environment testing; partner payload flight proposals.
Small-scale in-space robotic construction, structural inspection, and modular assembly experiment.
ENABLING THE
NEXT SPACE ECONOMY.
Vinastra initiates commercial operations through a focused beachhead in space robotics and digital-twin control systems before scaling toward orbital industrial infrastructure.
Space Robotics
High-dexterity robotic manipulators, autonomous docking end-effectors, component joining tools, and robotic servicing systems.
ISAM Systems
In-space servicing, assembly, and manufacturing platforms supporting satellite life-extension and modular spacecraft assembly.
Digital Twin & Autonomy
Autonomous task planning, kinematic simulation, metrology inspection software, and ground mission supervision suites.
Space Resources
Long-term extraterrestrial mineral processing, purification technology, and space-based manufacturing feedstock systems.
- Research & development contracts
- Ground prototype development
- Simulation software licensing
- Robotic construction subsystems
- Digital-twin autonomy platform
- Construction-control software
- Orbital payload partnerships
- ISAM mission collaborations
- Joint technology testbeds
- In-space contract manufacturing
- Asteroid resource processing
- Spacecraft servicing & logistics
ENGINEERING THE
FUTURE TOGETHER.
Building autonomous space infrastructure requires interdisciplinary engineering, institutional collaboration, and world-class DeepTech talent.
Universities & Research Labs
Robotics joint testing, computational simulations, student research, and peer-reviewed technical publications.
Space Agencies & Programs
Technology-development grant programs, ISAM mission studies, and space autonomy validation architectures.
Industrial Technology Partners
Hardware suppliers in robotics, sensors, wire-arc additive manufacturing, and space-grade embedded systems.
Incubators & Investors
Seed capital, aerospace advisory, customer discovery, and prototype validation acceleration.
BUILD THE INTELLIGENCE
BEHIND SPACE CONSTRUCTION.
Vinastra focuses defensibility in the most complex, foundational domain: autonomous industrial construction and verified robotic assembly in space.
Control Software
Proprietary mission logic, dynamic task sequencing, autonomous replanning algorithms, and robotic fleet coordination protocols.
Digital Twin
Sub-millimeter blueprint-to-reality verification engines, structural progress verification, and anomaly classification models.
Robotic Procedures
Validated additive manufacturing toolpaths, modular component positioning routines, and automated fault-recovery sequences.
Experimental Data
Empirical ground prototype datasets serving as the foundation for training future autonomous deep-space construction models.
Planned IP Portfolio
Developing patentable robotic joining mechanisms, novel end-effector interfaces, and proprietary construction system architectures.
FUND THE FIRST PROOF OF
AUTONOMOUS CONSTRUCTION.
Proposed seed capital raise to build and validate ASCS Prototype-1 on Earth, delivering investor-grade technical proof.
Robotic manipulators, mobile mobility base, optical/LiDAR sensor suites, additive printhead, and joining end-effectors.
Digital-twin platform, autonomous mission planner, closed-loop machine-vision metrology, and supervisory control HUD.
Core technical hires: robotics/mechatronics, AI/CV engineers, CAD/structural engineers, and specialized advisors.
Laboratory test fixtures, structural materials, environmental simulation testing, and partner flight preparations.
Patent filings, legal compliance, engineering documentation, corporate governance, and company runway.
THE NEXT INDUSTRIAL
FRONTIER IS IN SPACE.
Join Vinastra in developing the autonomous construction technology that could enable future space factories.