PILLAR 01
Direct CAD Ingestion
Converting parametric 3D CAD models directly into multi-arm robotic toolpaths and collision-free assembly sequences, eliminating manual operator pendant teaching.
 VINASTRA
AEROSPACE
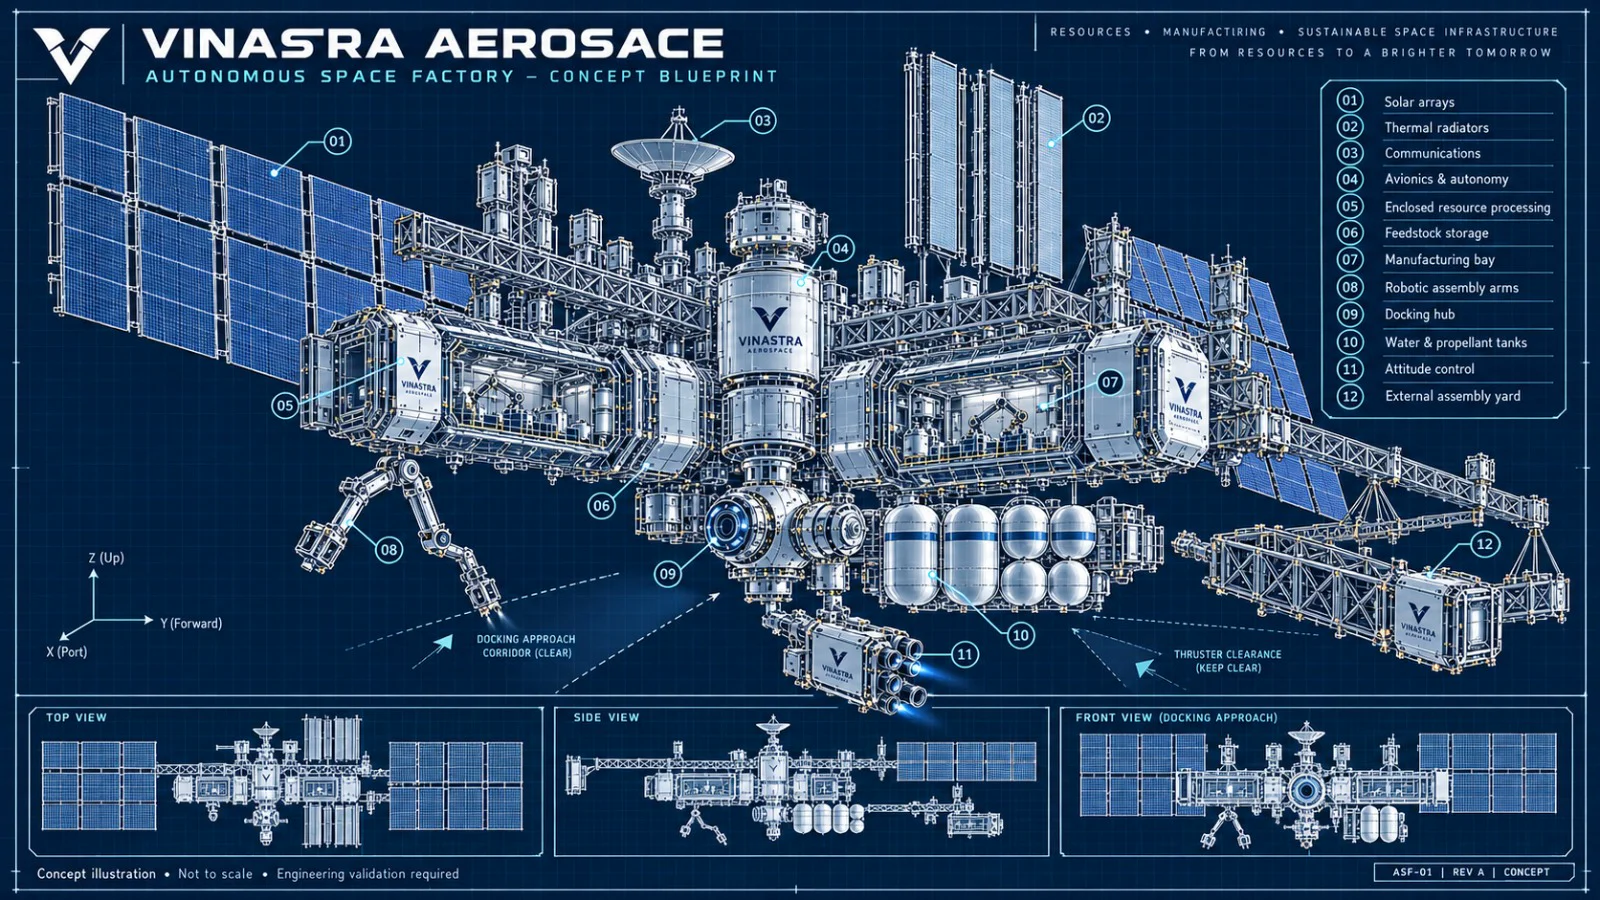
Before committing mission hardware to orbit, Vinastra is systematically proving the autonomous assembly loop in ground laboratories. Our research program focuses on CAD translation, robotic kinematics, additive composite joining, and closed-loop optical metrology.
The primary goal of Prototype-1 is to demonstrate an autonomous fabrication and assembly loop inside a laboratory cleanroom before advancing to space-qualification testing:
Converting parametric 3D CAD models directly into multi-arm robotic toolpaths and collision-free assembly sequences, eliminating manual operator pendant teaching.
Continuous extrusion and joining of carbon-fiber reinforced thermoplastics, forming rigid structural nodes connecting modular tubular struts.
Sub-millimeter bidirectional telemetry between physical robotic joints and the digital simulation, validating inverse kinematics, torque limits, and thermal expansion.
Structured-light 3D scanning measuring real-time structural geometry against nominal tolerances, flagging any angular misalignment or thermal warp.
Injecting artificial errors (dropped struts, displaced nodes) into the testbed to verify that the planner autonomously detects the error, replans the trajectory, and repairs the assembly.
Real-time browser-based telemetry HUD displaying multi-angle vision feeds, torque readouts, and state machines with one-click supervisory pause and manual override.
Every phase builds upon empirical test data and physical milestones achieved in preceding steps:
| PHASE | CORE FOCUS & OBJECTIVES | TARGET TIMELINE | STATUS |
|---|---|---|---|
| PHASE 01 | Foundation & Architecture: ASCS specification, physics engine setup, kinematic modeling | 2026 | ACTIVE IN R&D |
| PHASE 02 | Prototype-1 Ground Demonstrator: Laboratory robotics cell, CAD assembly loop, optical metrology | Months 1–18 | PROPOSED SEED GOAL |
| PHASE 03 | Integrated In-Situ Cell: Vacuum-thermal chamber testing, continuous composite joining, stress testing | Months 18–36 | PROPOSED TARGET |
| PHASE 04 | Orbital Flight Demonstration: Hosted orbital tech-demo payload validating microgravity robotic joining | 2030+ | PROPOSED TARGET |
| PHASE 05 | Commercial ISAM Services: Orbital servicing, structural expansion, satellite solar array deployment | Long-Term | STRATEGIC TARGET |
| PHASE 06 | Autonomous Space Factory: Modular orbital platform for deep-space manufacturing and refining | Multi-Decade | LONG-TERM VISION |
DISCLAIMER: TIMELINES, PHASES, AND MILESTONES REPRESENT PROPOSED ENGINEERING OBJECTIVES SUBJECT TO CAPITAL RAISES, RESEARCH PARTNERSHIPS, AND TECHNICAL PROGRESS. NO DEPLOYED ORBITAL CAPABILITY IS CLAIMED AT THIS STAGE.