SUBSYSTEM 01
Autonomous Mission Planner
Decomposes high-level CAD assembly models into discrete, collision-free robotic trajectory graphs. If an end-effector slips or a joint fails to latch, the planner dynamically recalculates paths locally without halting the mission.
SUBSYSTEM 02
High-Fidelity Digital Twin
Maintains an exact continuous mathematical and physics model of the orbital platform. Real-time sensor feedback streams into the digital twin, allowing operators on Earth to simulate and qualify complex moves before physical execution.
SUBSYSTEM 03
Robotic Manipulators & Tooling
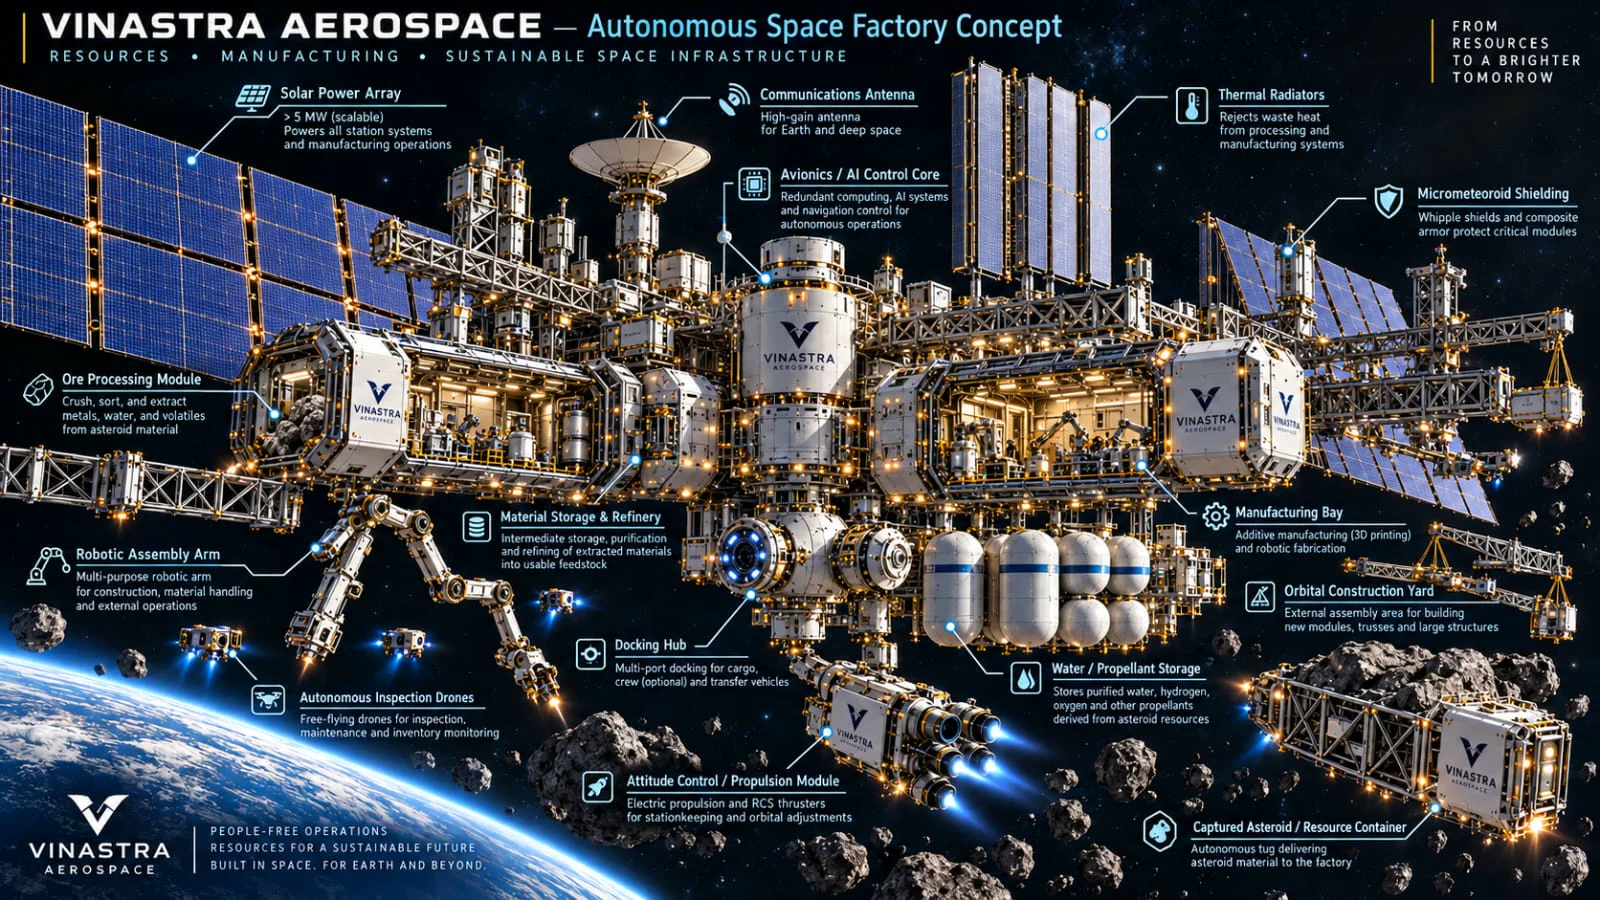
Multi-axis articulated robotic arms equipped with quick-change end-effectors: structural latching clamps, composite continuous-extrusion nozzles, laser welding heads, and tactile torque sensors for precision fastenings.
SUBSYSTEM 04
Closed-Loop Machine Vision
Stereoscopic cameras, time-of-flight depth sensors, and structured-light scanners performing sub-millimeter metrology. Computer vision detects microscopic deflections, joint gaps, and surface warps, streaming error deltas directly to the planner.
SUBSYSTEM 05
Supervisory Ground Control HUD
Web-native telemetry dashboard delivering low-bandwidth operational visualization to mission engineers on Earth. Ground operators maintain ultimate supervisory authority with one-click pause, safe-mode abort, and manual intervention overrides.
INTEGRATION LAYER
Edge Compute & RTOS
Radiation-tolerant edge processing unit running a deterministic real-time operating system (RTOS), guaranteeing sub-millisecond control loops for robotic stabilization and attitude compensation during heavy assembly maneuvers.